Felis
A cat-inspired robot with an actuated spine.
*Co-first authors†Project Lead
- Code, Coming soon
- Technical report, Coming soon
Teaser video not delivered yet
A cat-inspired legged robot with an actuated universal-joint spine, designed to right itself in midair, walk, turn, jump, and dance with only six motors.
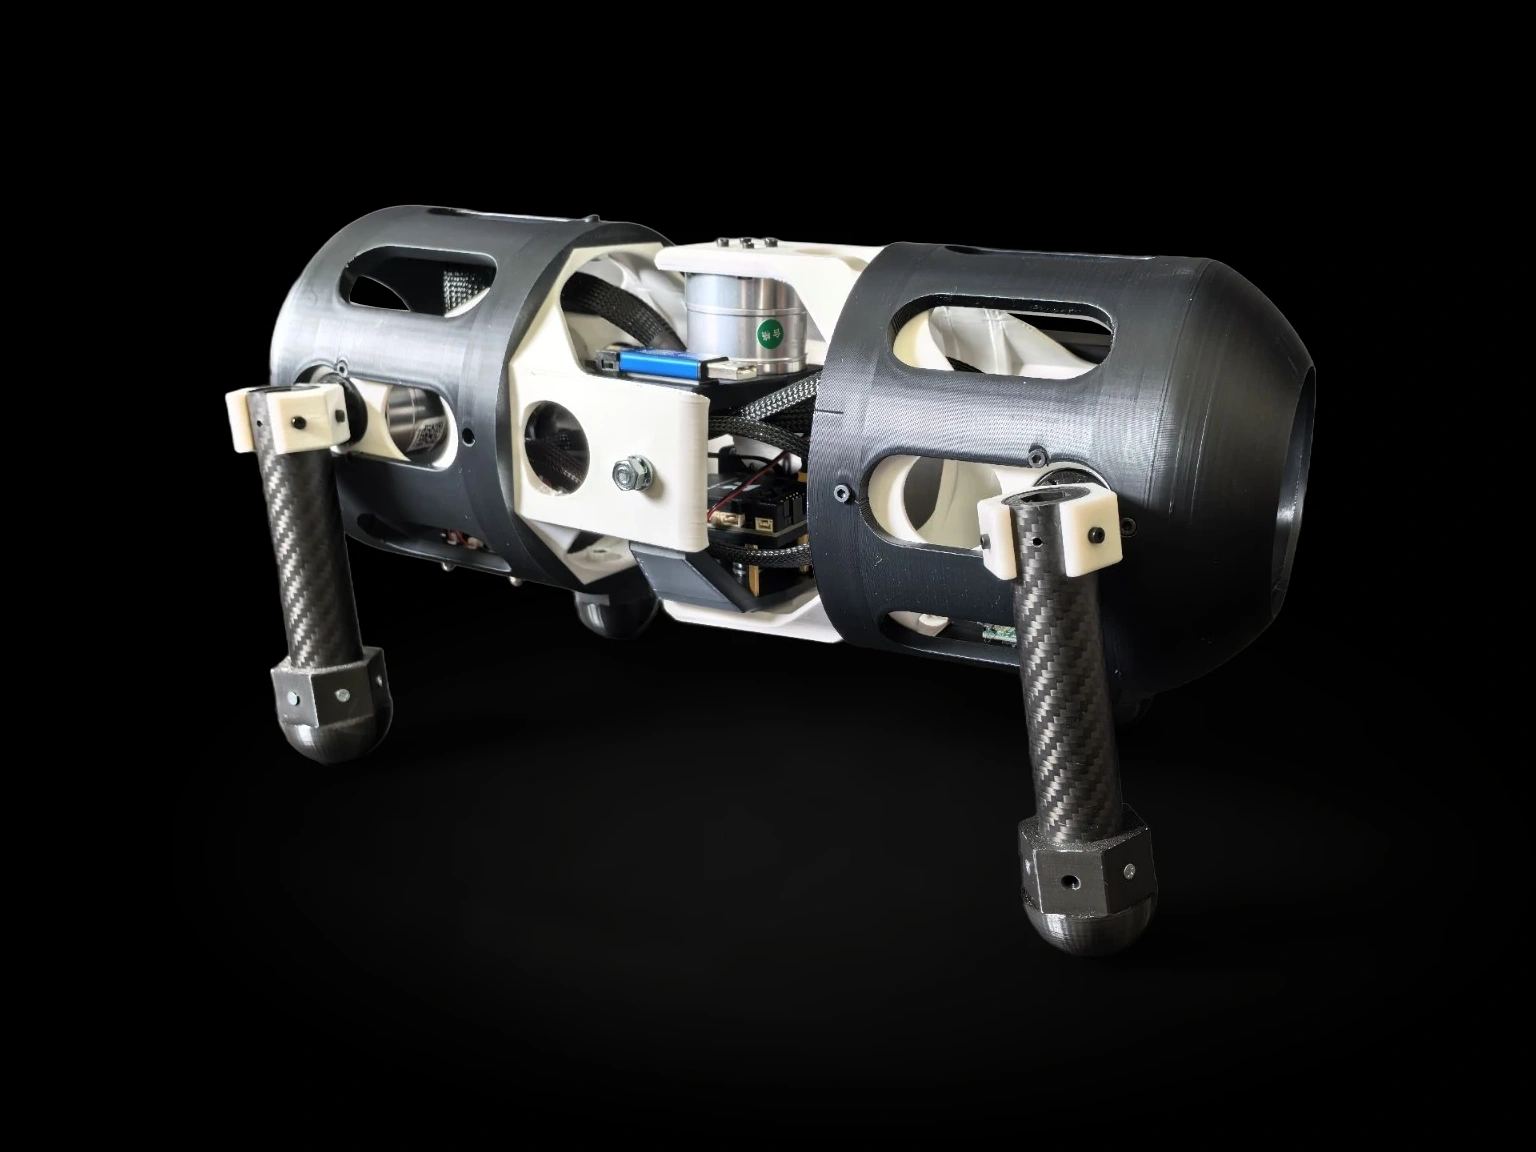
Photo not delivered yet
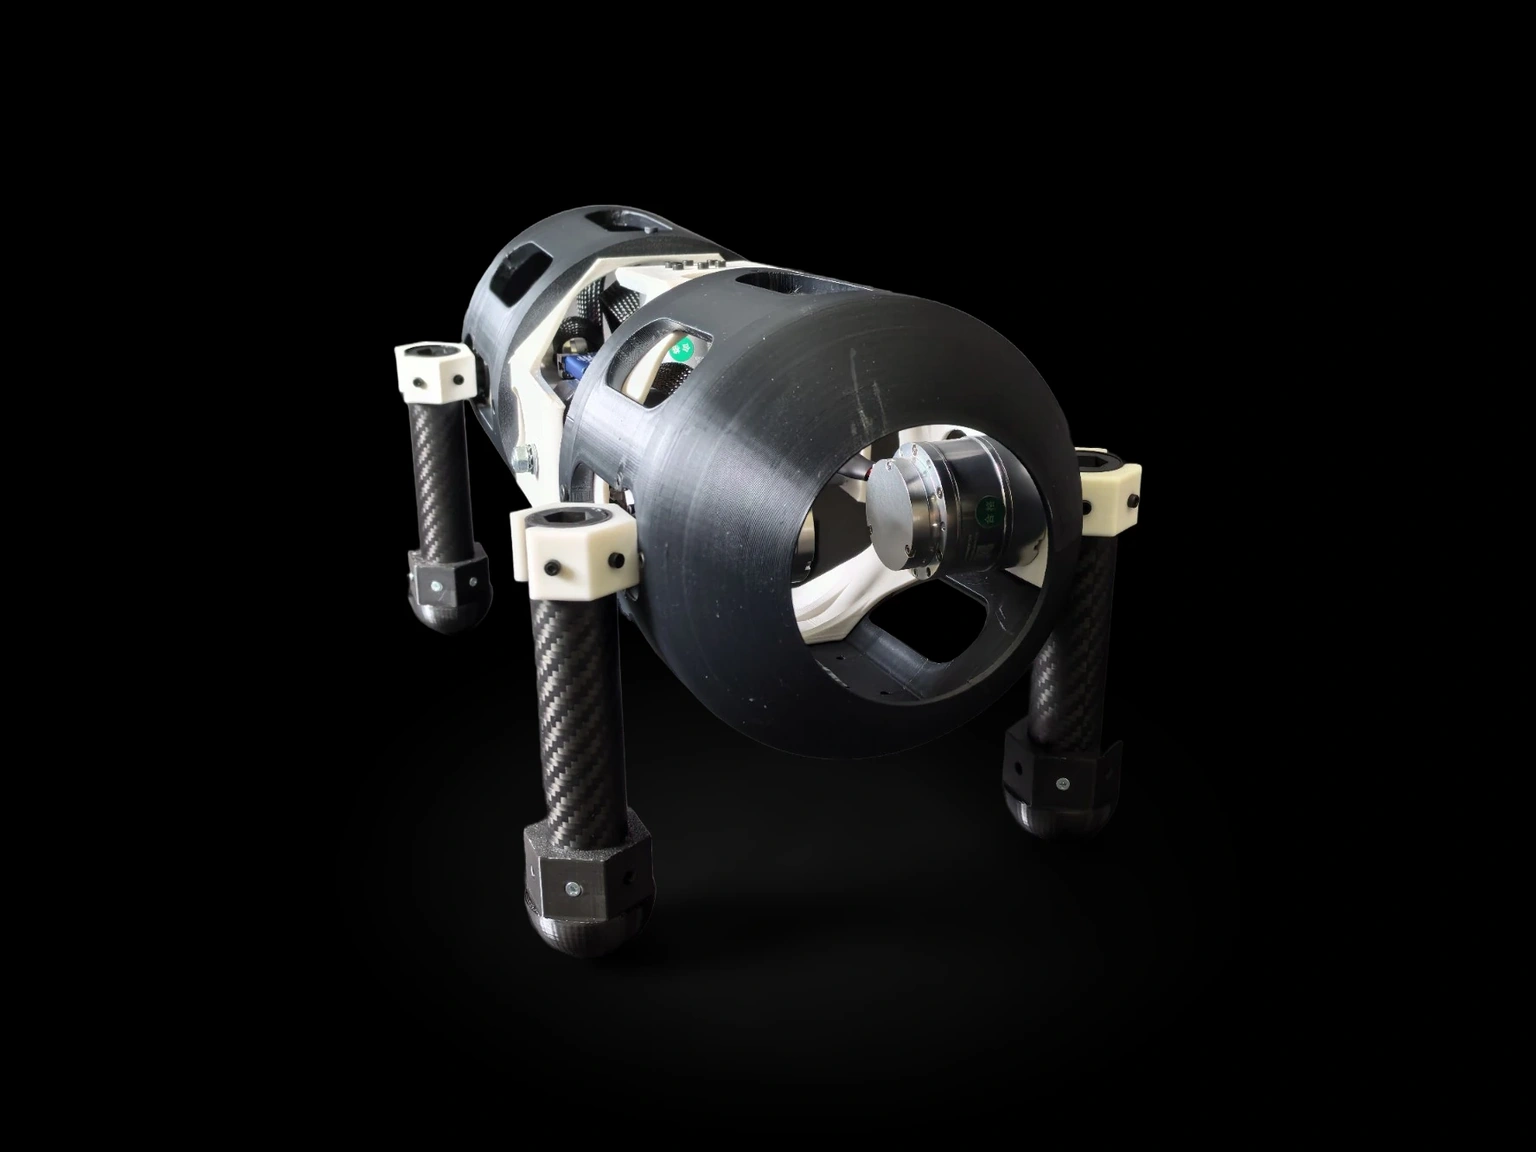
Photo not delivered yet
The robot as built.
Actuation moves from the legs to the spine.
A falling cat lands on its feet by bending and twisting its spine, so that the front and rear halves of its body rotate against each other. Shape change alone turns it over, with no net angular momentum. Most legged robots keep a rigid trunk and put many motors in the legs. We move the actuation into the body instead. Felis joins two body segments with a motor-driven two-axis universal joint at the waist and uses one motor per leg, six in total, half as many as a conventional quadruped. In physics simulation, the spine lets the robot right itself from an upside-down fall before touchdown. On the ground it walks forward and backward, turns in place, jumps and moves in time with music. An actuated spine can take over work usually done by leg motors, which could make legged robots lighter and simpler, with fewer motors.
Righting itself in midair.
Released upside down in physics simulation, Felis turns over and lands on its feet.
Video not delivered yet
- Released upside down0.08 s
- The body turns over0.34 s
- Nearly upright0.54 s
- Legs reach down0.62 s
- Touchdown0.66 s
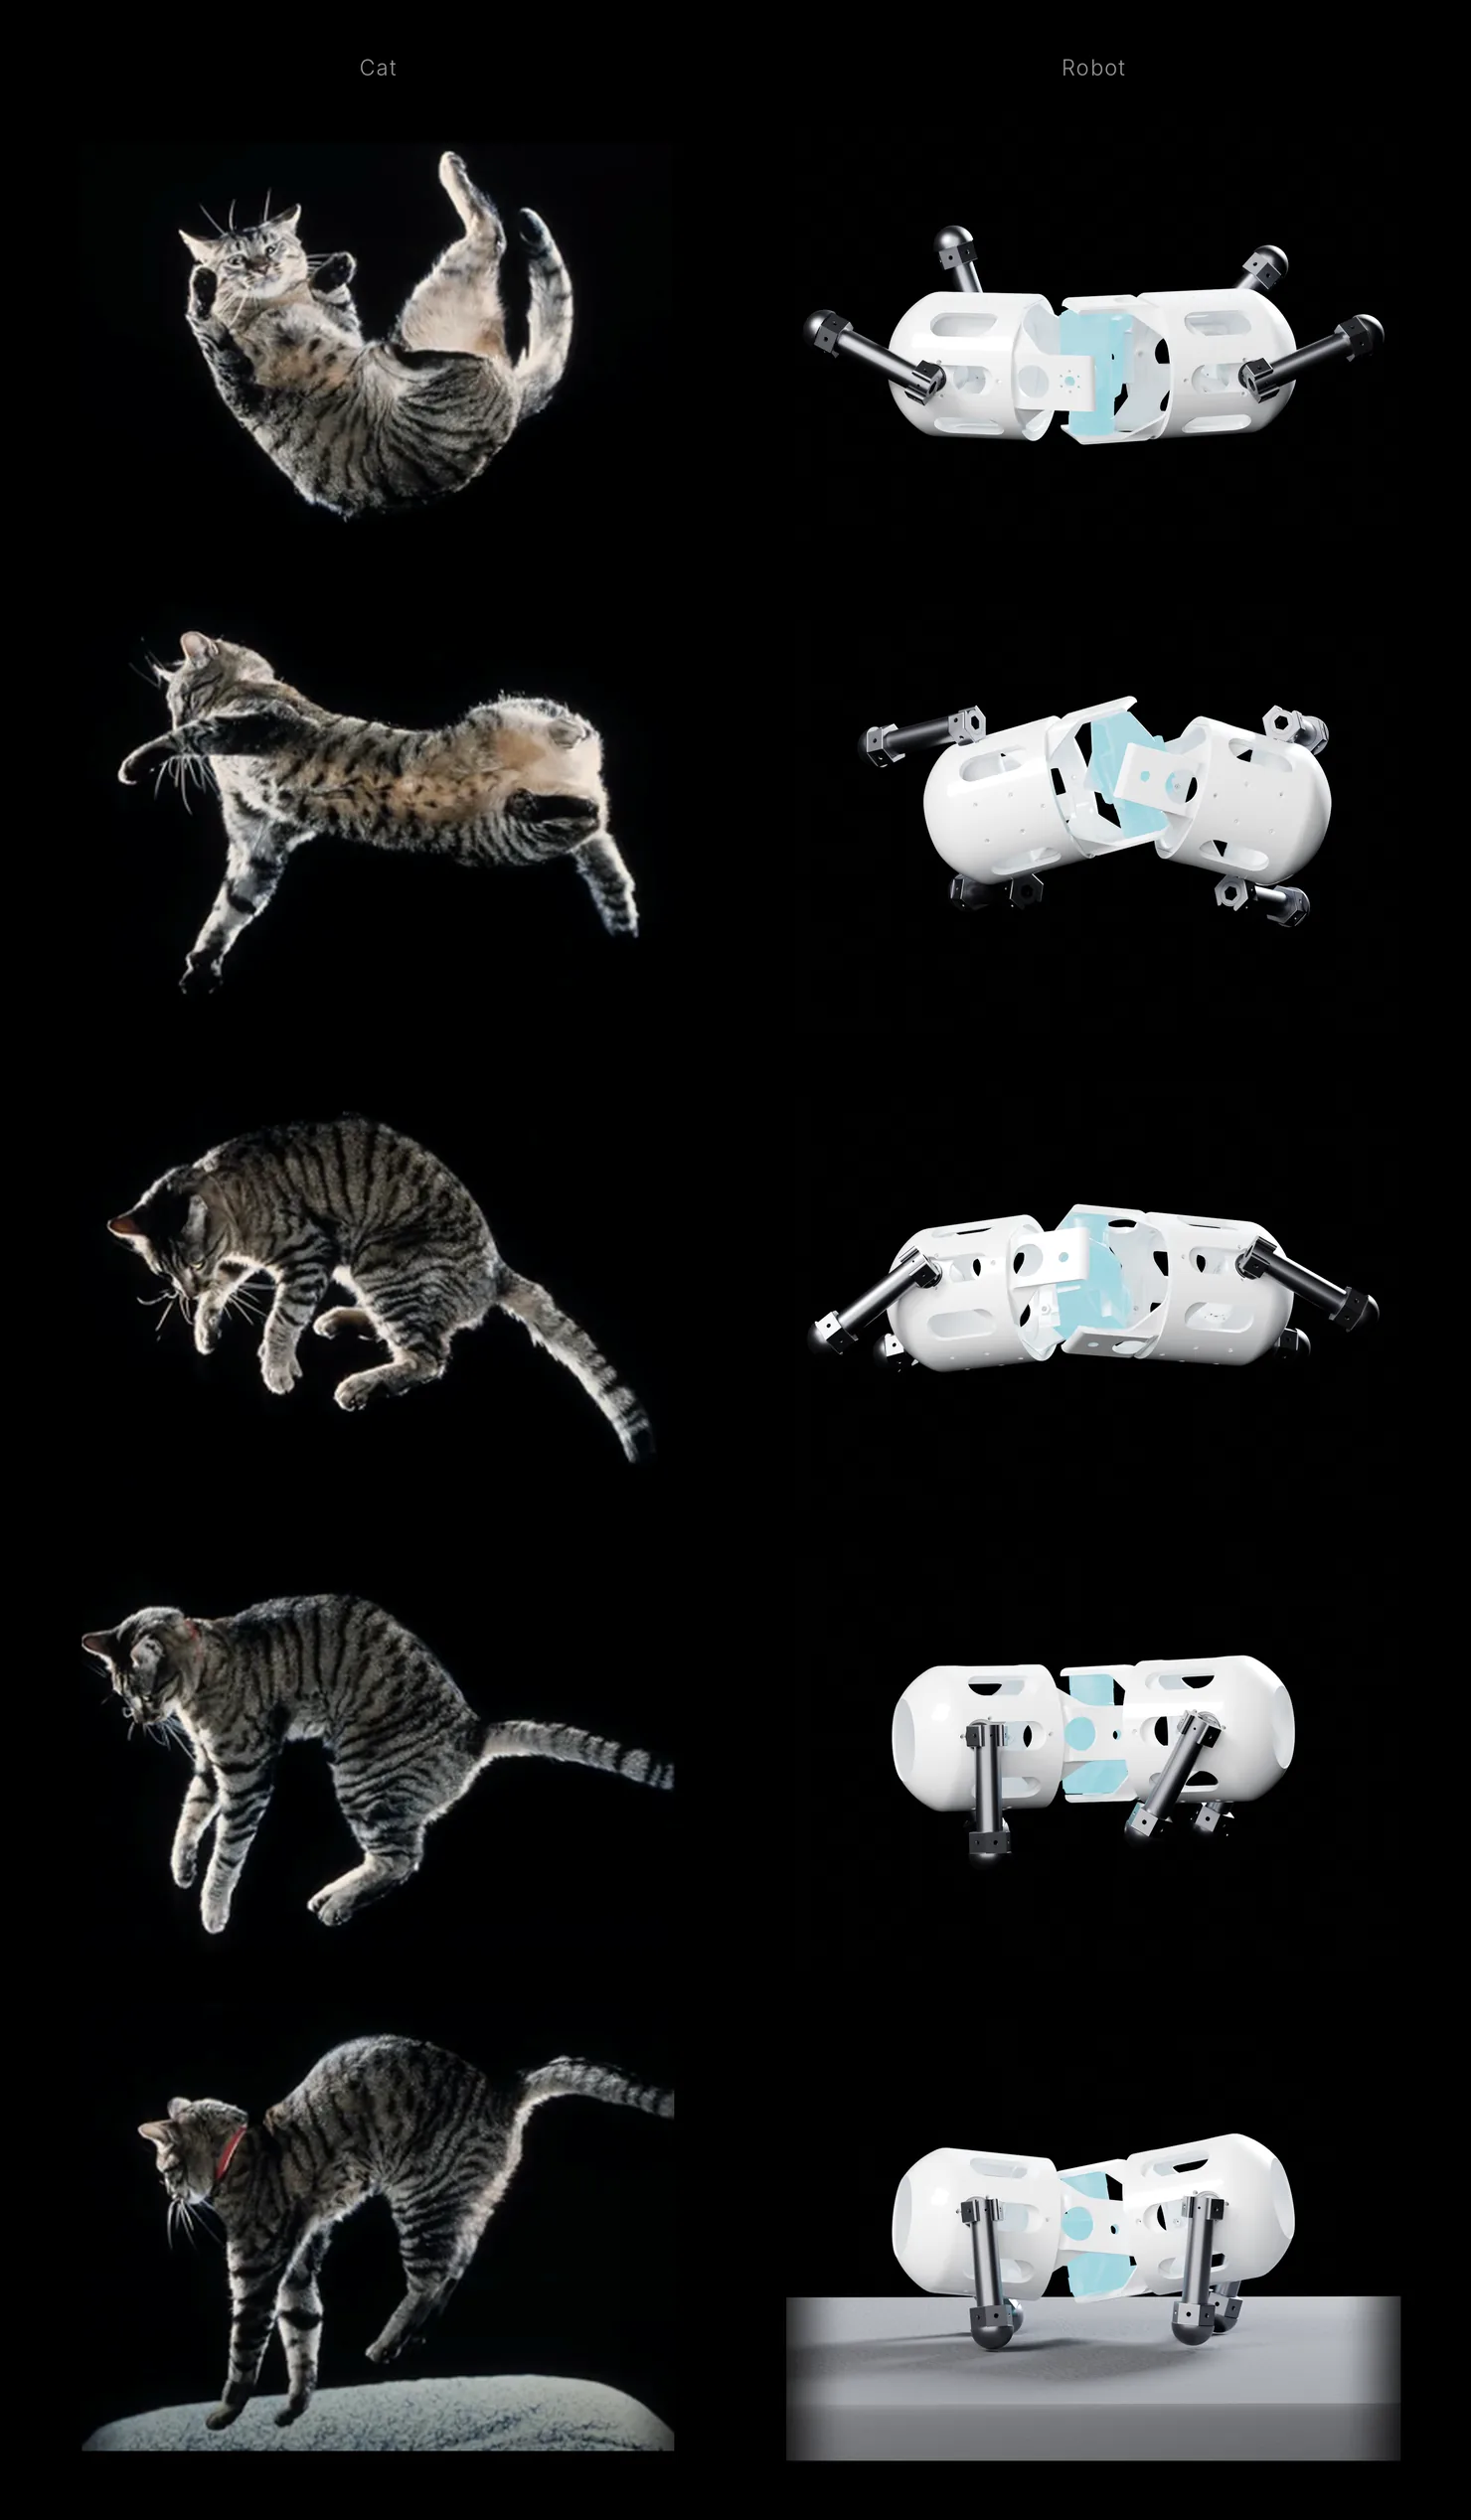
Figure not delivered yet
One motor per leg.
Forward and backward, turning, and jumping. Each motion plays as a studio render, with the physics simulation in the corner.
Simulation not delivered yet
Render not delivered yet
Walking forward
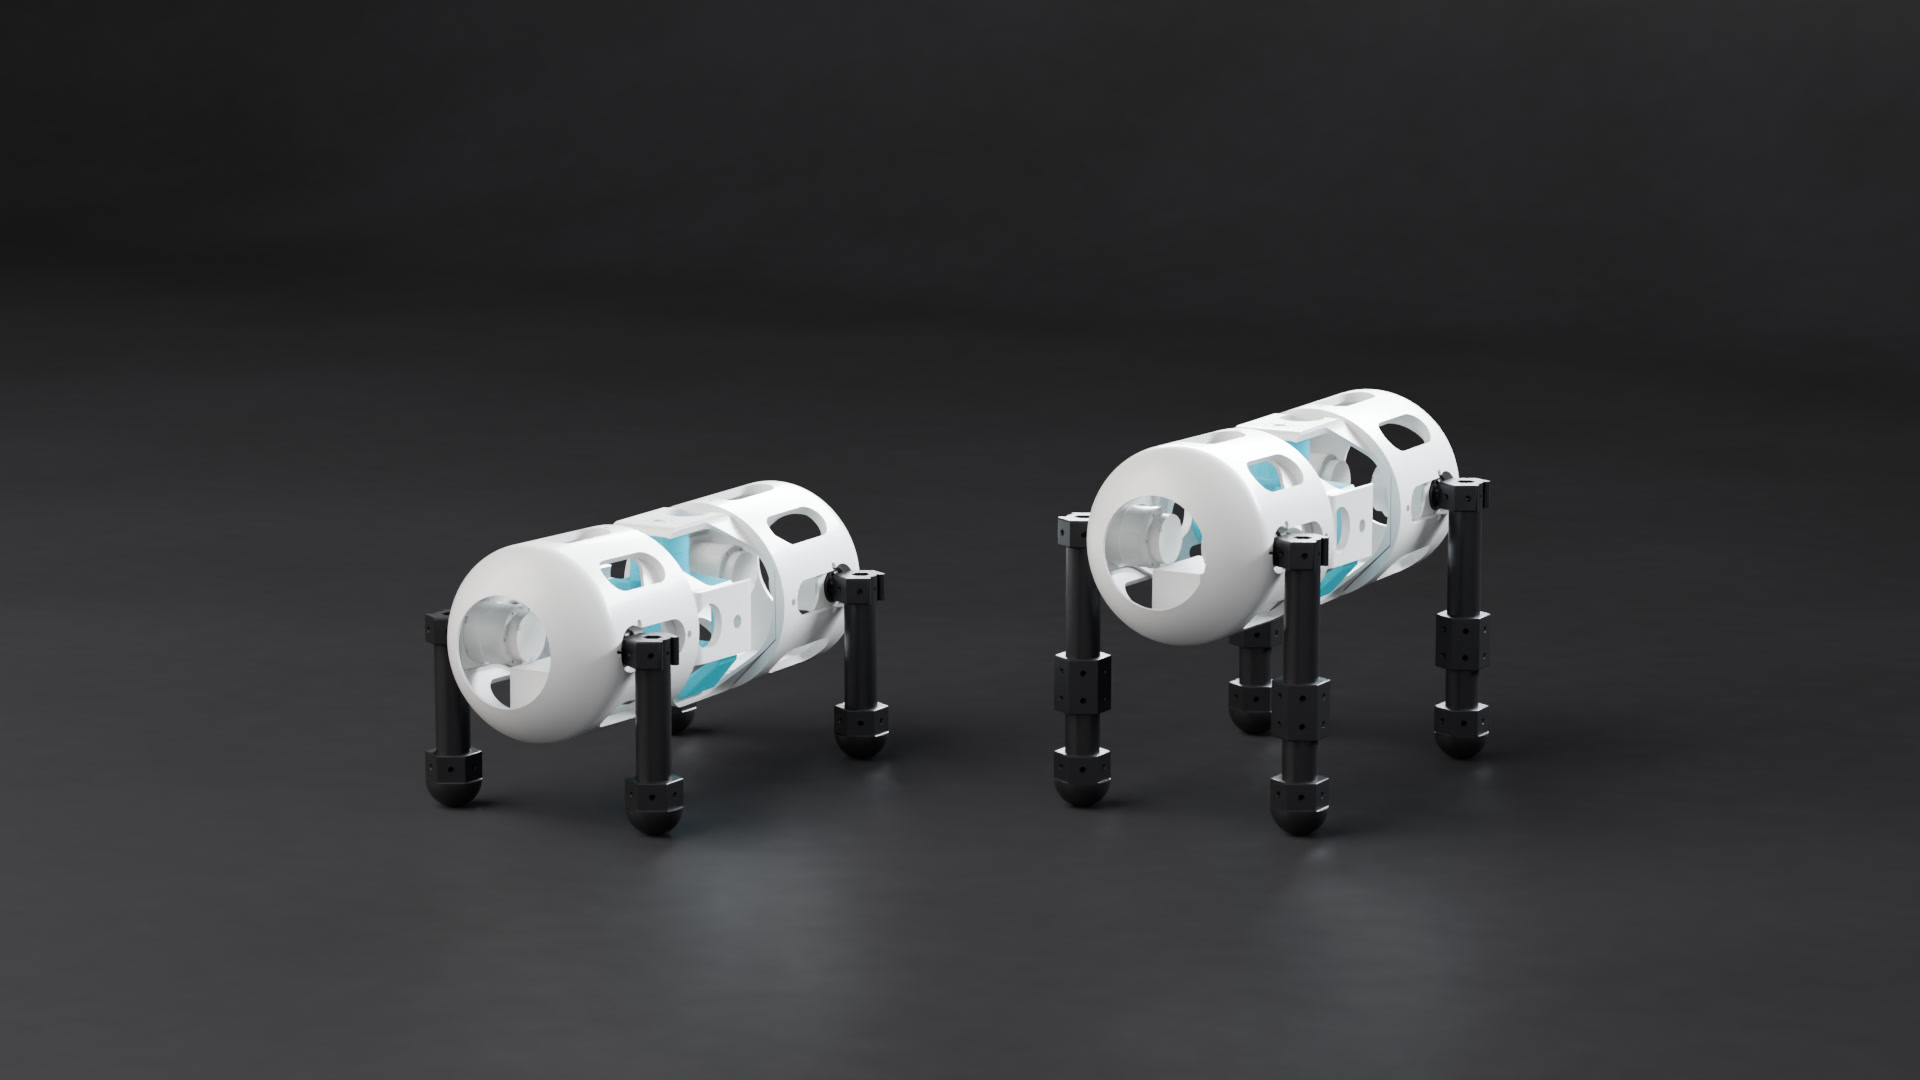
New parts, same six motors.
Felis takes add-on modules. The first is a longer leg. A connector and a second rod make each leg about half again as long and add no motors. Here it walks forward on the longer legs, in physics simulation.
Comparison image not delivered yet
Simulation not delivered yet
Render not delivered yet
Walking forward on longer legs
Moving in time with music.
Three songs, each staged in its own look. The physics simulation plays in the lower-left corner.
Video not delivered yet
Video not delivered yet
Video not delivered yet
Music excerpts are used for non-commercial research demonstration only. All rights belong to their respective owners.
Timeline
- 2023HKUThe ideaThe idea, and the first simulation environments, built and validated for a quadruped cat, a quadruped dog and an astronaut.With Zeshi Yang (SFU)Advisors: Taku Komura, Wenping Wang
- 2024–2025HKU & UPennFirst and second robotsThe first two versions of the robot.With Ken Suzuki, WeiHsi Chen and Cynthia SungAdvisors: Lingjie Liu, Cynthia Sung
- 2025–2026MITThird robotThe third version, the robot shown on this page.With Pengfei Ye and Yuxiang MaAdvisor: Wojciech Matusik
Reading list
Felis builds on more than a century of work on how a falling cat turns over, and on decades of legged robots with articulated bodies and few motors. Robots have turned themselves over in midair by bending their bodies, swinging tails or moving their legs. Spines have helped legged robots run, turn and even walk without leg motors. Robots have also danced to music. This list collects the work we draw on. We want to bring these ideas together in a small robot that is practical to build and use.
The falling cat
10 works
-
1894
Des mouvements que certains animaux exécutent pour retomber sur leurs pieds, lorsqu'ils sont précipités d'un lieu élevé
Chronophotographs of a cat dropped back-down and turning over in midair.
-
1936
Das Umdrehen der fallenden Katze in der Luft
Describes how the cat bends and twists its body to turn over.
-
1969
A dynamical explanation of the falling cat phenomenon
Two bodies that bend but do not twist relative to each other can turn over with zero angular momentum.
-
1989
Gauge kinematics of deformable bodies
Rotation produced by a cycle of shape changes, explained as a geometric phase, with the cat as an example.
-
1993
Gauge theory of the falling cat
The two-body falling cat recast in the language of gauge theory.
-
1998
A distributed control model for the air-righting reflex of a cat
A multibody cat model that turns over quickly and then holds its orientation.
-
2008
Active tails enhance arboreal acrobatics in geckos
Geckos right themselves in midair by swinging their tails.
-
2012
Tail-assisted pitch control in lizards, robots and dinosaurs
Lizards and a lizard-sized robot control their pitch in flight by moving the tail.
-
2019
Falling Felines and Fundamental Physics
A book-length history of the falling-cat problem and the physics around it.
-
2021
Geometry, Mechanics, and Control in Action for the Falling Cat
A monograph on the geometry, mechanics and control of the falling cat.
Robots that right themselves in midair
52 works
-
1990
Dynamics and optimal control of a legged robot in flight phase
Optimal reorientation of a legged robot in flight by changing its shape, in theory and simulation.
-
1991
Physical explication and realization of the turning motion of a cat by analysis and experiment using a robot cat
A robot cat with an actuated backbone turns 180° within 0.6 s after being released upside down.
-
1992
Elucidation of twisting motion of a falling cat and its realization by a robot
A jointed two-column model of the cat's twist, realised on a robot.
-
1993
A study on the control of the rotational maneuvers of a robot in midair
A robot turns over in midair with zero angular momentum by changing its shape, shown in experiments.
-
1994
Posture detection and landing control of robot thrown in midair
Rate gyros estimate a thrown robot's attitude in flight, and its legs are turned toward the ground for landing.
-
2000
Final-state control of a two-link cat robot by feedforward torque inputs
Two rigid bodies joined by two orthogonal waist torques reach a target attitude, in simulation.
-
2000
3D posture control by using the cat-turn motion
A "double cat-turn" about two perpendicular axes changes a body's attitude in three dimensions.
-
2008
Posture control of a free falling robotic cat for soft landing using reinforcement learning
Reinforcement learning of the landing posture for a two-segment cat model, in simulation.
-
2012
Control of a free-falling cat by policy-based reinforcement learning
Policy-gradient learning of falling-cat control, in simulation.
-
2013
Falling cat robot lands on its feet
A two-body falling-cat robot model with input torques that turn it over from any starting angle, checked in simulation.
-
2013
Modeling, design and simulation of falling and landing process in a robotic cat
Models falling-cat robots from two to eight links, optimizes their dimensions and plans a staged landing.
-
2014
Orienting in mid-air through configuration changes to achieve a rolling landing for reducing impact after a fall
Cat-inspired midair reorientation of jointed robots ahead of a rolling landing.
-
2014
Understanding of falling cat phenomenon and realization by robot
A review of the robot-cat line, including a robot with vertebra-like backbones that rights itself.
-
2016
Research on trajectory planning of a robot inspired by free-falling cat based on modified quasi-Newton algorithm
Plans the turning trajectory of a two-cylinder falling-cat robot model in simulation.
-
2017
Research on time-optimal falling trajectory of a free-falling cat robot
Time-optimal righting trajectories for a two-body cat robot with a waist hinge, tested on a virtual prototype.
-
2017
Effect of swing legs on turning motion of a free-falling cat robot
Studies how swinging the legs changes the turning motion of a falling-cat robot model.
-
2017
Singularity-free planning for a robot cat free-fall with control delay: role of limbs and tail
Free-fall planning for a cat model with two waist rotations, limbs and a tail, in simulation.
-
2018
Falling cat robot feedback acquisition and its evaluation
Fast sensing for the CMU Biorobotics Lab's falling-cat robot during a fall of about half a second.
-
2018
Stickman: towards a human scale acrobatic robot
A human-scale acrobatic robot controls its rotation in flight by tucking its body.
-
2019
SpaceBok: a dynamic legged robot for space exploration
A legged robot built for dynamic jumping in low gravity.
-
2021
Design and experimental validation of reorientation manoeuvres for a free falling robot inspired from the cat righting reflex
An articulated robot rolls 180° in free fall through cycles of its internal joints, shown in drop experiments.
-
2021
Online trajectory optimization for dynamic aerial motions of a quadruped robot
Online trajectory optimization for flips, barrel rolls and spins of a quadruped in the air.
-
2022
Cat-like jumping and landing of legged robots in low gravity using deep reinforcement learning
Learned leg motions reorient a legged robot in flight so that it lands on its feet in low gravity.
-
2022
Mini Cheetah, the falling cat: a case study in machine learning and trajectory optimization for robot acrobatics
A quadruped rights itself in midair with its legs, using learning and trajectory optimization.
-
2022
Planification et réalisation de manœuvres de réorientation de robots en chute libre [Planning and execution of reorientation manoeuvres for free-falling robots]
Fast and multi-axis reorientation of free-falling robots inspired by the cat, with a 180-degree pitch turn on a test platform.
-
2022
Reorientation of free-falling legged robots
Two manoeuvres inspired by the cat's reflex reorient a free-falling legged robot in roll and pitch.
-
2022
A review of research on falling cat phenomenon and development of bio-falling cat robot
Reviews research on the falling cat and on robots that imitate it.
-
2022
On the dynamics and control of a squirrel locking its head/eyes toward a fixed spot for safe landing while its body is tumbling in air
A multi-segment model reorients its body by joint motion in the air while the head stays fixed.
-
2022
Online optimal landing control of the MIT Mini Cheetah
Online optimal landing control for a quadruped dropped from height.
-
2023
Reactive landing controller for quadruped robots
A reactive controller for landing quadruped robots.
-
2023
Evaluation of legged robot landing capability under aggressive linear and angular velocities
Measures how well legged robots can land at high linear and angular velocities.
-
2023
Integrated attitude and landing control for quadruped robots in asteroid landing mission scenarios using reinforcement learning
Learned attitude and landing control for quadruped robots landing on asteroids.
-
2024
Reinforcement learning and sim-to-real transfer of reorientation and landing control for quadruped robots on asteroids
Learned reorientation and landing control for quadrupeds in low gravity, transferred from simulation to hardware.
-
2024
Robust orientation correction control for a falling quadruped with an active spine
A real-time controller inspired by the cat's righting reflex reorients a falling quadruped with a two-DoF active spine.
-
2024
In-flight attitude control of a quadruped using deep reinforcement learning
A small quadruped controls its attitude during free fall using only its legs, with a learned policy.
-
2024
Reorientation of a bio-cat falling legged robot driven by pneumatic muscles with energy optimization
A falling legged robot with a flexible pneumatic-muscle spine reorients itself with minimum energy.
-
2024
Neural control and learning of a gecko-inspired robot for aerial self-righting
Neural control and learning for aerial self-righting of gecko-inspired robot variants.
-
2024
SpaceHopper: a small-scale legged robot for exploring low-gravity celestial bodies
A small three-legged robot for low gravity that controls its attitude in flight with its legs.
-
2024
Modeling and in-flight torso attitude stabilization of a jumping quadruped
Stabilizes the torso attitude of a jumping quadruped in flight by moving its legs.
-
2024
Model predictive attitude control of a jumping-and-flying quadruped for planetary exploration
Model predictive attitude control of a quadruped during long flights.
-
2025
Olympus: a jumping quadruped for planetary exploration utilizing reinforcement learning for in-flight attitude control
A jumping quadruped for low-gravity exploration with learned in-flight attitude control.
-
2025
A generic continuous multi-joint spinal robotic system for agile and accurate behaviors with GNN-MPC method
A continuous multi-joint robotic spine, controlled with learned dynamics and model predictive control, flips itself in free fall.
-
2025
Global reorientation of a free-fall multibody system using periodical joint motions – theory and motion planning
Periodic joint motions reorient a free-falling multibody system to any attitude.
-
2025
Global reorientation of a free-fall robotic system using reconstruction loss-based deep learning method—theory and comparison
A learned method for the global reorientation of a free-falling multibody robot.
-
2025
High accuracy aerial maneuvers on legged robots using variational integrator discretized trajectory optimization
Whole-body trajectory optimization for precise aerial manoeuvres of legged robots.
-
2025
Curriculum learning for landing of quadruped robots
Curriculum reinforcement learning for landing quadruped robots.
-
2025
Monopedal robot branch-to-branch leaping and landing inspired by squirrel balance control
A one-legged robot leaps between branches and lands, using balance strategies seen in squirrels.
-
2025
Conception et validation expérimentale d'un robot mobile robuste pouvant se réorienter en chute libre [Design and experimental validation of a robust mobile robot able to reorient itself in free fall]
Design and experimental validation of a robust mobile robot that reorients itself in free fall.
-
2026
S-Cheetah: a novel quadrupedal robot with a 3-DOF active spine learning agile locomotion
A quadruped with a three-DoF active spine learns agile running and midair righting, in simulation.
-
2026
Nonlocomotory robotic strategies for dynamic rotation control in terrestrial robots: a review
A review of strategies such as tails and reaction wheels for controlling body rotation in terrestrial robots.
-
2026
Towards low-gravity planetary exploration using reinforcement learning for walking, jumping, and in-flight attitude control
Learned walking, jumping and in-flight attitude control for a quadruped in low gravity.
-
2026
Residual-learning-based landing control with gravity estimation for quadruped robot in low-gravity scenarios
Learned landing control with gravity estimation for a quadruped in low gravity.
Tails, reaction wheels and other appendages
43 works
-
2011
A lizard-inspired active tail enables rapid maneuvers and dynamic stabilization in a terrestrial robot
A small robot with a one-DoF active tail stabilizes and reorients itself in midair.
-
2012
Tail assisted dynamic self righting
A measure of how well a tail rights a robot in midair, tested on two robots of very different size.
-
2012
Tails in biomimetic design: analysis, simulation, and experiment
Compares tails with reaction wheels for reorienting a body.
-
2012
Dynamic turning of 13 cm robot comparing tail and differential drive
A small legged robot turns quickly with a tail, compared with differential drive.
-
2013
A nonlinear feedback controller for aerial self-righting by a tailed robot
Nonlinear feedback control lets a tailed robot right itself in the air.
-
2013
Precise dynamic turning of a 10 cm legged robot on a low friction surface using a tail
A tail gives a small legged robot precise turns on a slippery surface.
-
2013
Rapid turning at high-speed: inspirations from the cheetah's tail
A cheetah-inspired tail for rapid turning at high speed.
-
2013
Controlling aerial maneuvering of a miniature jumping robot using its tail
A tail controls the attitude of a miniature jumping robot in the air.
-
2014
Rapid acceleration and braking: inspirations from the cheetah's tail
A cheetah-inspired tail for rapid acceleration and braking.
-
2014
A bio-inspired hopping kangaroo robot with an active tail
A hopping kangaroo robot with an actively controlled tail.
-
2015
On the conical motion of a two-degree-of-freedom tail inspired by the cheetah
Conical motion of a two-degree-of-freedom tail for body reorientation.
-
2015
MSU Tailbot: controlling aerial maneuver of a miniature-tailed jumping robot
A miniature jumping robot controls its aerial manoeuvres with a tail.
-
2015
Parallel composition of templates for tail-energized planar hopping
A tail energizes and stabilizes planar hopping.
-
2015
Tail-assisted rigid and compliant legged leaping
A tail assists leaping with rigid and with compliant legs.
-
2016
Robotic vertical jumping agility via series-elastic power modulation
The jumping robot Salto controls its pitch in flight with an inertial tail.
-
2016
Comparative design, scaling, and control of appendages for inertial reorientation
Compares tails, reaction wheels and moving body segments, including an actuated body joint, for reorienting in flight.
-
2016
Frontal plane stabilization and hopping with a 2DOF tail
A two-degree-of-freedom tail stabilizes a hopping robot in the frontal plane.
-
2016
On designing an active tail for legged robots: simplifying control via decoupling of control objectives
Designs an active tail for legged robots with decoupled control objectives.
-
2017
Repetitive extreme-acceleration (14-g) spatial jumping with Salto-1P
Repeated jumping in three dimensions, with a tail for pitch and thrusters for roll and yaw.
-
2018
Modeling and control of an articulated tail for maneuvering a reduced degree of freedom legged robot
A tail steers and balances a quadruped whose legs only propel it.
-
2018
Steering of an underactuated legged robot through terrain contact with an active tail
A tail steers an underactuated legged robot by touching the ground.
-
2018
Precision jumping limits from flight-phase control in Salto-1P
How flight-phase control with a tail limits the precision of jumping.
-
2019
Towards jumping locomotion for quadruped robots on the moon
A quadruped built for lunar gravity controls its pitch in flight with a reaction wheel.
-
2020
Dynamics and aerial attitude control for rapid emergency deployment of the agile ground robot AGRO
A cat-inspired ground robot uses its wheels as reaction wheels to control its attitude when dropped.
-
2021
Dynamic modeling, analysis, and design synthesis of a reduced complexity quadruped with a serpentine robotic tail
A quadruped with single-DoF legs and a serpentine tail for righting and maneuvering, in simulation.
-
2021
Dynamic modeling, analysis, and comparative study of a quadruped with bio-inspired robotic tails
Compares a quadruped model with different bio-inspired robotic tails.
-
2021
Real-time planning and nonlinear control for quadrupedal locomotion with articulated tails
Real-time planning and control for quadruped locomotion with articulated tails.
-
2021
Enabling dynamic behaviors with aerodynamic drag in lightweight tails
Lightweight tails that use aerodynamic drag enable dynamic behaviours, including reorientation in the air.
-
2021
Tails stabilize landing of gliding geckos crashing head-first into tree trunks
Tails stabilize the head-first landing of gliding geckos, tested with a soft robot model.
-
2022
Design and experimental validation of a monopod robot with 3-DoF morphable inertial tail for somersault
A one-legged robot with a three-degree-of-freedom morphable inertial tail performs somersaults.
-
2023
Towards safe landing of falling quadruped robots using a 3-DoF morphable inertial tail
A three-DoF tail mounted on a quadruped reorients it during falls for a safe landing.
-
2023
Combining tail and reaction wheel for underactuated spatial reorientation in robot falling with quadratic programming
A tail and a reaction wheel together reorient a falling robot in three dimensions.
-
2023
Enhanced balance for legged robots using reaction wheels
Pitch and roll reaction wheels improve the balance of a quadruped.
-
2023
Orientation control system: enhancing aerial maneuvers for quadruped robots
Two reaction wheels control a quadruped's roll and pitch during aerial manoeuvres.
-
2023
Proprioception and tail control enable extreme terrain traversal by quadruped robots
Proprioception and tail control let a quadruped cross extreme terrain.
-
2024
Enhanced aerial reorientation performance using a 3-DoF morphable inertial tail inspired by kangaroo rats
A kangaroo-rat-inspired morphable tail improves reorientation in the air.
-
2024
Manipulator as a tail: promoting dynamic stability for legged locomotion
A manipulator arm used as a tail improves the dynamic stability of a legged robot.
-
2024
Learning rapid turning, aerial reorientation, and balancing using manipulator as a tail
A quadruped learns to turn, reorient in the air and balance with an arm used as a tail.
-
2025
Jointed tails enhance control of three-dimensional body rotation
Jointed tails improve control of body rotation in three dimensions.
-
2025
Tethered variable inertial attitude control mechanisms through a modular jumping limbed robot
Attitude control by changing inertia on a modular jumping limbed robot.
-
2026
Enhanced quadruped locomotion via reaction wheels in low-gravity environments
Reaction wheels improve quadruped locomotion in low gravity.
-
2026
Underactuated multimodal jumping robot for extraterrestrial exploration
An underactuated jumping robot with reaction wheels for exploring other worlds.
-
2026
Dynamic modeling and attitude control of a reaction-wheel-based low-gravity bipedal hopper
A bipedal hopper controls its attitude with a reaction wheel in low gravity.
Spines and body joints in legged robots
62 works
-
1995
Control of vertebrate backbone system by using artificial rubber muscles (control of two-degree-of-freedom system by using three artificial rubber muscles)
A vertebra-like backbone with a two-degree-of-freedom bending joint driven by three artificial rubber muscles.
-
1999
Mechanical construction and computer architecture of the four-legged walking machine BISAM
A four-legged walking machine with an active body joint.
-
2005
Development of biomimetic quadruped walking robot with 2-DOF waist joint
A walking quadruped with a two-DoF waist joint.
-
2005
Discontinuous spinning gait of a quadruped walking robot with waist-joint
A quadruped turns in place by using its waist joint.
-
2007
From swimming to walking with a salamander robot driven by a spinal cord model
A salamander robot with an actuated spine and four single-motor legs swims and walks.
-
2007
Discontinuous zigzag gait planning of a quadruped walking robot with a waist-joint
A waist joint shifts the body sideways to keep a walking quadruped stable.
-
2010
Hysteresis in gait transition induced by changing waist joint stiffness of a quadruped robot driven by nonlinear oscillators with phase resetting
Changing the waist joint's stiffness changes a quadruped's gait transitions.
-
2010
Facilitating multi-modal locomotion in a quadruped robot utilizing passive oscillation of the spine structure
Passive oscillation of the spine lets a quadruped switch between gaits.
-
2010
Learning approach to study effect of flexible spine on running behavior of a quadruped robot
A learning approach to study how a flexible spine affects quadruped running.
-
2011
Effect of flexible spine on stability of a passive quadruped robot: experimental results
Experiments on how a flexible spine affects the stability of a passive quadruped.
-
2011
A study on trunk stiffness and gait stability in quadrupedal locomotion using musculoskeletal robot
Trunk stiffness and gait stability in a musculoskeletal quadruped modelled on the cat.
-
2011
Additional DOFs and sensors for bio-inspired locomotion: towards active spine, ankle joints, and feet for a quadruped robot
Adds an active spine, ankle joints and feet to a quadruped robot.
-
2012
Embodiment enables the spinal engine in quadruped robot locomotion
A quadruped with no actuated legs bounds, trots and turns by bending its spine.
-
2012
The function of the spine and its morphological effect in quadruped robot locomotion
The role of an actuated spine and its morphology in quadruped locomotion.
-
2013
Free-standing leaping experiments with a power-autonomous elastic-spined quadruped
Canid, a power-autonomous quadruped with an actuated elastic spine, makes free-standing leaps.
-
2013
Benefits of an active spine supported bounding locomotion with a small compliant quadruped robot
An actuated spine helps a small compliant quadruped bound.
-
2013
Salamandra robotica II: an amphibious robot to study salamander-like swimming and walking gaits
An amphibious salamander robot with a multi-joint trunk and one motor per leg.
-
2013
Spine dynamics as a computational resource in spine-driven quadruped locomotion
Uses the dynamics of a spine as a computational resource in spine-driven locomotion.
-
2013
The effect of spine actuation and stiffness on a pneumatically-driven quadruped robot for cheetah-like locomotion
How spine actuation and stiffness affect cheetah-like running of a pneumatic quadruped.
-
2013
Pneupard: a biomimetic musculoskeletal approach for a feline-inspired quadruped robot
A feline-inspired musculoskeletal quadruped robot.
-
2013
A bio-inspired quadruped robot with a global compliant spine
A quadruped robot with a compliant spine along its whole body.
-
2014
Spine as an engine: effect of spine morphology on spine-driven quadruped locomotion
How the shape of the spine affects locomotion when only the spine is actuated.
-
2014
Realization of three-dimensional walking of a cheetah-modeled bio-inspired quadruped robot
Three-dimensional walking of a musculoskeletal quadruped modelled on the cheetah.
-
2015
Cheetah-cub-S: steering of a quadruped robot using trunk motion
A small quadruped steers by bending its trunk.
-
2015
Comparing the effect of different spine and leg designs for a small bounding quadruped robot
Compares spine and leg designs on a small bounding quadruped.
-
2016
Model-based dynamic gait in a quadruped robot with waist actuation
A quadruped with single-motor rotating legs and an actuated waist runs with dynamic gaits.
-
2016
Dynamic bending of bionic flexible body driven by pneumatic artificial muscles (PAMs) for spinning gait of quadruped robot
A flexible body bent by pneumatic muscles lets a quadruped turn on the spot.
-
2016
Development of a flexible coupled spine mechanism for a small quadruped robot
A flexible coupled spine for a small cat-like quadruped.
-
2016
Hybrid quadruped bounding with a passive compliant spine and asymmetric segmented body
Bounding with a passive compliant spine and an asymmetric segmented body.
-
2017
Core actuation promotes self-manipulability on a direct-drive quadrupedal robot
Actuation at the body core enlarges a quadruped's reachable workspace for leaping and self-manipulation.
-
2017
Empirical validation of a spined sagittal-plane quadrupedal model
Tests a spined sagittal-plane model of a quadruped against a robot.
-
2017
Bio-inspired control strategy study for the quadruped robot with a segmented spine
Bio-inspired control of a quadruped with a segmented spine.
-
2017
Study on quadruped bounding with a passive compliant spine
Bounding of a quadruped with a passive compliant spine.
-
2018
Design, simulation, and testing of a flexible actuated spine for quadruped robots
In Laika, a quadruped with unactuated legs, the tensegrity spine alone lifts each foot.
-
2018
Turning strategies for the bounding quadruped robot with an active spine
A bounding quadruped turns by bending its active spine.
-
2018
Analysis of using an active artificial spine in a quadruped robot
Analyses the use of an active artificial spine in a quadruped.
-
2019
Development of the neurorobotic mouse
NeRmo, a robotic mouse with a flexible spine.
-
2019
Affordances and control of a spine morphology for robotic quadrupedal locomotion
A doctoral study of what a spine offers a quadruped and how to control it.
-
2019
Walking pattern generation algorithm with waist motion for improving energy efficiency of quadruped robot
Walking patterns with waist motion to save energy, in simulation.
-
2019
Synchronization of non-linear oscillators for neurobiologically inspired control on a bionic parallel waist of legged robot
Coupled oscillators control a bio-inspired parallel waist of a legged robot.
-
2019
Toward a gecko-inspired, climbing soft robot
A soft gecko-inspired robot climbs with bending actuators in its legs and torso.
-
2020
Towards rich motion skills with the lightweight quadruped robot Serval
A lightweight quadruped with an actuated multi-axis spine.
-
2020
Decentralized control mechanism for body–limb coordination in quadruped running
Decentralized control coordinates an active trunk with the legs in quadruped running.
-
2020
Realization of a bio-inspired cheetah robot with a flexible spine
A cheetah-inspired robot with a flexible spine.
-
2020
Study on effects of spinal joint for running quadruped robots
Effects of a spinal joint on running quadruped robots.
-
2022
Coordinating tiny limbs and long bodies: geometric mechanics of lizard terrestrial swimming
A robot with two body joints and four one-DoF limbs moves on granular media, coordinated by geometric mechanics.
-
2022
Development of a small-sized quadruped robotic rat capable of multimodal motions
SQuRo, a small robotic rat with an actuated waist that turns tightly and recovers from falls.
-
2022
A cheetah-mimicking quadruped running robot with 2DOF articulated trunk
A cheetah-like running quadruped with a two-degree-of-freedom trunk that lengthens its stride.
-
2023
Lateral flexion of a compliant spine improves motor performance in a bioinspired mouse robot
Sideways bending of a compliant spine improves a mouse robot's stability, stride, speed and turning.
-
2023
Dynamic locomotion of a quadruped robot with active spine via model predictive control
Dynamic locomotion of a quadruped with an active spine using model predictive control.
-
2023
High-speed running quadruped robot with a multi-joint spine adopting a 1DoF closed-loop linkage
A fast running quadruped with a multi-joint spine driven by a single-degree-of-freedom linkage.
-
2023
Optimal kinematic design of a robotic lizard using four-bar and five-bar mechanisms
A robotic lizard whose body motion drives its legs through linkages.
-
2025
A bio-inspired adjustable posture quadruped robot with laterally undulating spine for terradynamically challenging environments
A quadruped whose two halves are joined by a yaw-and-pitch body joint, with one hip servo per leg, crosses difficult terrain with an undulating spine.
-
2025
Design and gait control of a quadruped robot with a waist joint
A quadruped with four single-joint legs and a waist joint that helps it steer.
-
2025
Enhancing the flexibility of a quadruped robot with a 2-DOF active spine using nonlinear model predictive control
A quadruped with a two-DoF active spine, controlled by nonlinear model predictive control.
-
2025
Latissimus-dorsi-inspired wire mechanism for improving energy efficiency of quadruped robot locomotion
A wire mechanism inspired by the latissimus dorsi improves a quadruped's energy efficiency.
-
2025
Latissimus-dorsi-inspired trunk torsion mechanism for quadruped robot spine design
A spine design in which the trunk twists, inspired by the latissimus dorsi.
-
2025
Quadrupedal spine control strategies: exploring correlations between system dynamic responses and human perspectives
Relates spine control strategies of a quadruped to how people perceive its motion.
-
2025
Design and evaluation of lizard-inspired single-actuated robot
A lizard-inspired robot propels and turns itself with a single actuator.
-
2025
Mechanical design of a quadruped robot with a two degree of freedom compliant spine
Mechanical design of a quadruped with a two-degree-of-freedom compliant spine.
-
2026
Flexible-torso quadruped robots: biomimetic principles, structural designs, and torso-limb coordination – a review
A review of flexible-torso quadruped robots.
-
2026
Unlocking fast robotic locomotor propulsion through dynamic spine-leg synergy
Dynamic coordination of spine and legs speeds up a small quadruped robot.
Legged robots with few motors
26 works
-
1998
SCOUT: a simple quadruped that walks, climbs, and runs
One motor per leg, with a prototype that walks, turns and climbs a step, while running and stair climbing are shown in simulation.
-
1999
The design and control of Scout I, a simple quadruped robot
Design and control of Scout I, a simple quadruped with one actuated joint per leg.
-
1999
Stable open loop walking in quadruped robots with stick legs
Stable open-loop walking of a quadruped with stick legs and one motor per leg.
-
2001
RHex: a simple and highly mobile hexapod robot
A hexapod with one motor per leg that moves fast over rough terrain.
-
2001
Quadruped robot running with a bounding gait
A quadruped with one actuator per leg runs with a bounding gait.
-
2004
Model-based dynamic self-righting maneuvers for a hexapedal robot
RHex rights itself on the ground with dynamic, model-based leg maneuvers.
-
2004
"Cheap" rapid locomotion of a quadruped robot: self-stabilization of bounding gait
A quadruped driven only at the hips bounds with self-stabilization.
-
2004
Rotary gallop in the untethered quadrupedal robot Scout II
A rotary gallop that traces a circle on a quadruped with one motor per leg.
-
2004
An approach to design a quadruped walking machine with a single actuator
Design of a quadruped walking machine driven by one actuator.
-
2005
Modeling and experiments of untethered quadrupedal running with a bounding gait: the Scout II robot
Scout II runs untethered with a bounding gait, with one hip actuator per leg.
-
2005
Exploiting body dynamics for controlling a running quadruped robot
One control parameter sets the speed of a running quadruped that exploits its body dynamics.
-
2006
PAW: a hybrid wheeled-leg robot
A wheeled-leg quadruped with one hip motor per leg.
-
2006
Bounding gait in a hybrid wheeled-leg robot
Bounding on a wheeled-leg quadruped with one hip motor per leg.
-
2010
Bounding with active wheels and liftoff angle velocity adjustment
Bounding with actuated wheels, with forward speed rising as the legs lift off at larger angles.
-
2011
Running and turning control of a quadruped robot with compliant legs in bounding gait
Running and turning of a quadruped with compliant legs and one actuator per leg.
-
2013
Toward a vocabulary of legged leaping
A repertoire of leaps for a hexapod with one motor per leg.
-
2017
The merits of passive compliant joints in legged locomotion: fast learning, superior energy efficiency and versatile sensing in a quadruped robot
Passive compliant knees help a quadruped with actuated hips learn gaits quickly and walk efficiently.
-
2019
Omni-directional gait of a passive-spine hexapod
An omni-directional gait for a hexapod with a passive spine.
-
2020
Learning to walk in the real world with minimal human effort
A quadruped with planar legs learns to walk and to turn in place in the real world.
-
2020
Influence of compliant joints in four-legged robots
Simulates four-legged robots with hip servos and compliant knees and spine.
-
2021
A legged soft robot platform for dynamic locomotion
An untethered soft quadruped for dynamic locomotion driven by four motors.
-
2022
Simulation and analysis of a single actuated quadruped robot
Simulation and analysis of a quadruped driven by a single actuator.
-
2023
CurveQuad: a centimeter-scale origami quadruped that leverages curved creases to self-fold and crawl with one motor
A centimetre-scale origami quadruped that folds itself and crawls with a single motor.
-
2025
Synergy-based robotic quadruped leveraging passivity for natural intelligence and behavioural diversity
A quadruped whose twelve joints are driven by four actuators through synergies, with diverse behaviours.
-
2026
Dynamic modeling and MPC for locomotion of tendon-driven soft quadruped
Modeling and model predictive control of a tendon-driven soft quadruped with four actuators.
-
2026
Vibration of soft, twisted beams for underactuated quadrupedal locomotion
Vibrating twisted beams drive an underactuated quadruped with two motors.
Modular and reconfigurable legged robots
8 works
-
2010
Design, construction and a compliant gait of “ModPod”: a modular hexpod robot
A modular hexapod whose body segments are joined by an actuated two-DoF universal spine.
-
2012
Laboratory on legs: an architecture for adjustable morphology with legged robots
Leg and body modules that combine into different legged robots, including the spined quadruped Canid.
-
2018
Rising STAR: a highly reconfigurable sprawl tuned robot
A highly reconfigurable legged robot that adjusts its sprawl.
-
2020
An open torque-controlled modular robot architecture for legged locomotion research
An open, modular architecture of actuators and legs for building small legged robots.
-
2021
Self-reconfigurable multilegged robot swarms collectively accomplish challenging terradynamic tasks
Legged robots that link into larger multilegged robots to cross difficult terrain together.
-
2022
Origaker: a novel multi-mimicry quadruped robot based on a metamorphic mechanism
A quadruped built on a metamorphic mechanism that can take on several animal-like forms.
-
2026
Agile legged locomotion in reconfigurable modular robots
One-DoF leg modules combine into different robots that learn agile locomotion.
-
2026
Maneuverable multilegged locomotion through anisotropically arranged soft backbones in a single-actuator modular miniature robot
A modular miniature robot driven by one actuator that steers through the arrangement of its soft backbones.
Learning to control spines and simple bodies
9 works
-
2004
Automated gait adaptation for legged robots
Automated tuning of the gait of the hexapod RHex.
-
2019
Learning active spine behaviors for dynamic and efficient locomotion in quadruped robots
Deep reinforcement learning of active spine motion for fast, efficient quadruped gaits, in simulation.
-
2021
Biomimetic quadruped robot with a spinal joint and optimal spinal motion via reinforcement learning
A quadruped with one spinal joint learns its spine motion with reinforcement learning.
-
2024
Spined torso renders advanced mobility for quadrupedal locomotion
A spined torso improves a quadruped's mobility, with learned trotting and bounding.
-
2024
A robust quadruped robot with twisting waist for flexible motions
A quadruped with a twisting waist and fewer leg joints, controlled through imitation learning.
-
2025
KLEIYN: a quadruped robot with an active waist for both locomotion and wall climbing
A quadruped with an active waist that learns both walking and wall climbing.
-
2026
Pushing physical limits and uncovering motion templates of spine-based quadruped locomotion via reinforcement learning
Reinforcement learning uncovers spine motion templates for fast running and turning on a mouse robot.
-
2026
Gait optimization control of spinal quadruped robot based on deep reinforcement learning
Deep reinforcement learning with a central pattern generator optimizes the gait of a spined quadruped.
-
2026
Evaluation of an actuated spine in agile quadruped locomotion
Evaluates an actuated spine for learned agile quadruped skills.
Robots that dance to music
21 works
-
2005
From lamprey to humanoid: the design and control of a flexible spine belly dancing humanoid robot with inspiration from biology
A humanoid whose flexible spine performs belly dance.
-
2007
A dancing robot for rhythmic social interaction
Keepon, a small, simple robot, dances in time with the rhythm it perceives.
-
2009
Keepon: a playful robot for research, therapy, and entertainment
A small creature-like robot used in research and entertainment, including dancing to music.
-
2009
Rhythmic attention in child-robot dance play
Children and a small robot dance together to music.
-
2010
Design and study of a highly articulated mini lion-dance robot
A highly articulated four-legged robot that performs the lion dance.
-
2011
Aibo JukeBox – a robot dance interactive experience
The robot dog Aibo dances to songs chosen by users.
-
2011
The trials of hula hooping by a musculo-skeletal humanoid KOJIRO nearing dancing motions using the soft spine
A musculoskeletal humanoid hula-hoops with its soft spine, close to dance motions.
-
2013
Effects of robotic companionship on music enjoyment and agent perception
A robot that moves to music changes how people enjoy the music.
-
2015
Emotionally expressive dynamic physical behaviors in robots
Emotionally expressive movement in a robot that responds to music.
-
2017
Keep on dancing: effects of expressive motion mimicry
Effects of a robot mimicking a person's dance motion.
-
2018
Real-time dance generation to music for a legged robot
A quadruped generates dance moves to music in real time.
-
2022
Music and movement based dancing for a non-anthropomorphic robot
Dancing for a non-humanlike robot based on music and movement.
-
2023
Robot choreographer
A method for turning a script of dance moves into joint commands for a legged robot.
-
2023
DOC: differentiable optimal control for retargeting motions onto legged robots
Differentiable optimal control retargets expressive motions onto legged robots.
-
2023
Central pattern generators evolved for real-time adaptation to rhythmic stimuli
Evolved central pattern generators let a simulated quadruped adapt its gait to a rhythm.
-
2023
Toward cultures of rhythm in legged robots
Legged robots that pick up and pass on rhythms.
-
2024
May the dance be with you: dance generation framework for non-humanoids
A framework for generating dances for robots that are not humanoid.
-
2024
Mapping music onto robot joints for autonomous choreographies: PCA-based approach
Maps music onto robot joints for autonomous choreography.
-
2025
Music-driven legged robots: synchronized walking to rhythmic beats
A quadruped learns to walk with its steps synchronized to the musical beat.
-
2025
DFM: Deep Fourier Mimic for expressive dance motion learning
Expressive dance motions learned on a robot dog.
-
2026
QuadFM: foundational text-driven quadruped motion dataset for generation and control
A dataset of quadruped motions, including dance, for generation and control.